My work with SJTU Blue Fins connects state estimation to a physical underwater robot: sensing hardware, embedded interfaces, system integration, and hands-on debugging and maintenance.
The Platform
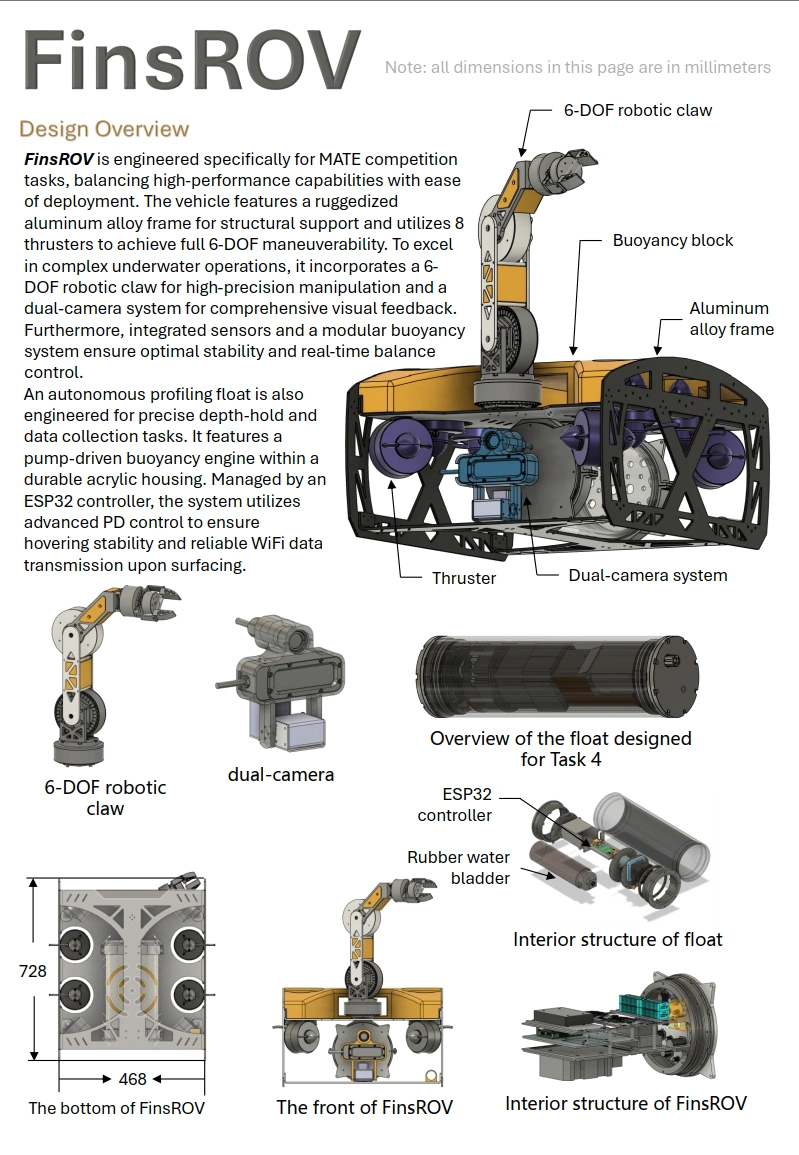
FinsROV is the Blue Fins team’s underwater robot for the MATE ROV competition. The vehicle combines an aluminum frame, a sealed electronics housing, eight thrusters, a gimbal-mounted binocular camera, and a manipulator for underwater tasks.
Four horizontal thrusters provide surge, sway, and yaw control; four vertical thrusters support heave, roll, and pitch. A Jetson Orin NX handles onboard communication and media, while a RoboMaster A-board with an STM32F4 MCU runs the real-time sensing and control stack. The ground station provides operator commands, live video, and telemetry.
My Focus: Estimation on Real Hardware
My focus is state estimation and hardware–software integration, supported by hands-on experience debugging and maintaining robots. The work connects sensor measurements, embedded processing, and the behavior of the actual machine.
Understand the robot's state
Connect IMU and pressure measurements to attitude and depth feedback.
Connect hardware and software
Work across physical sensor installation, embedded interfaces, and system telemetry.
Work with the real machine
Bring hands-on debugging, fault isolation, and maintenance experience to the robot.
The following sections describe the competition platform documented by the team and the system interfaces relevant to my work.
From Sensors to State Estimates
The competition platform uses a WHEELTEC H30 nine-axis IMU, sampled at 400 Hz, for orientation sensing. The team’s technical documentation describes Extended Kalman Filter (EKF) fusion for attitude estimation. The IMU’s physical installation and vibration isolation are part of the measurement path, alongside its communication interface and orientation relative to the vehicle.
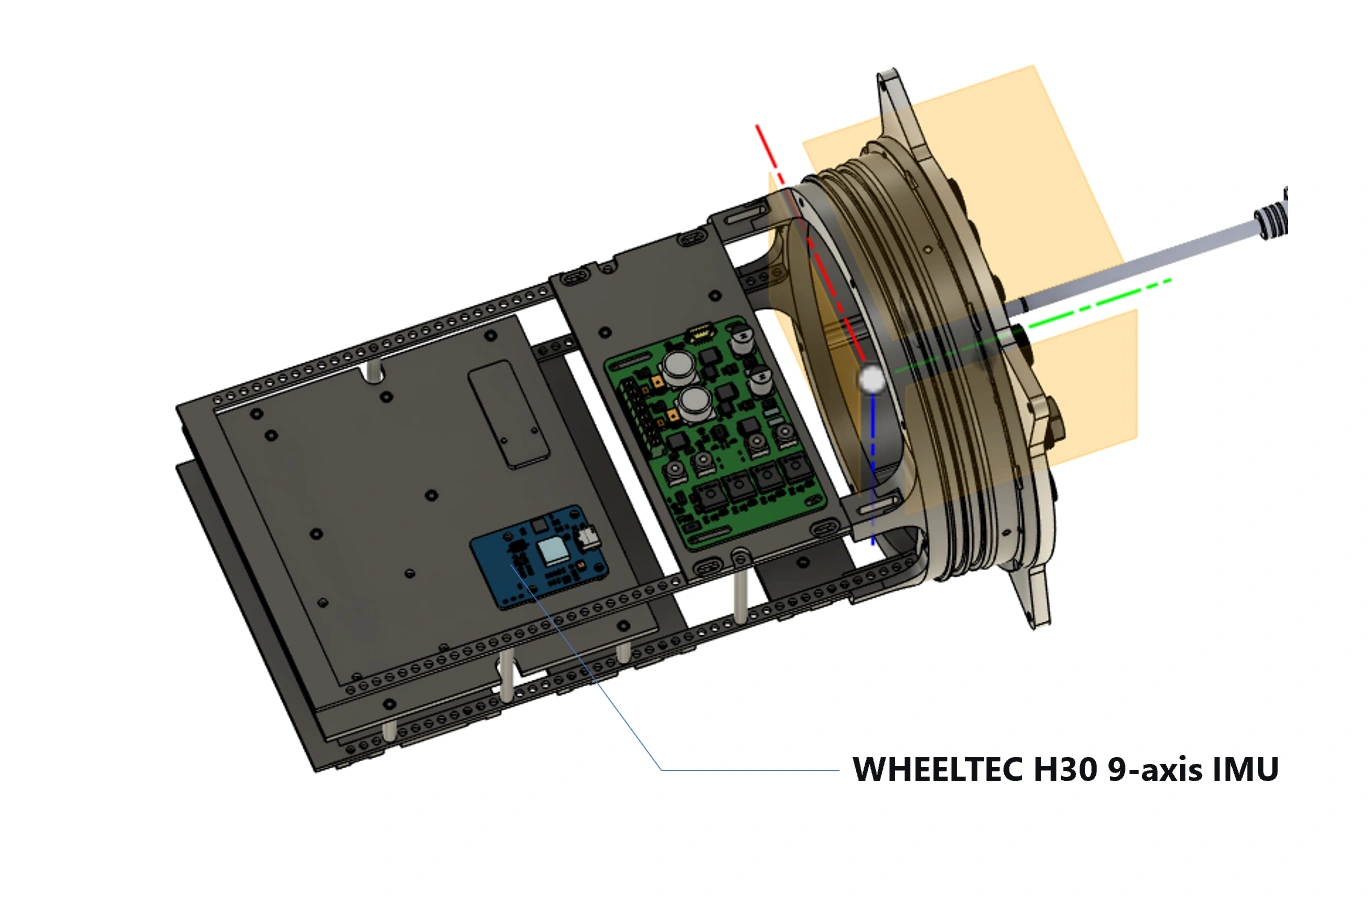
A separate PCM380 pressure sensor measures ambient water pressure for conversion to depth feedback. It supports RS485–Modbus communication. The documented estimator outputs emphasized here are attitude and depth, which support stabilization and depth holding.
H30 IMU · 400 HzEKF fusionAttitude feedback
PCM380 pressurePressure-to-depth conversionDepth feedback
Measurement paths summarized from the team's sensor description; the two rows represent separate attitude and depth signals.
Hardware–Software Integration
The A-board FineMote control stack connects sensors, communication buses, and actuators. It uses attitude and angular-rate feedback in cascaded PID control, with an independent depth controller. The controller maps the desired vehicle response to the eight thrusters.
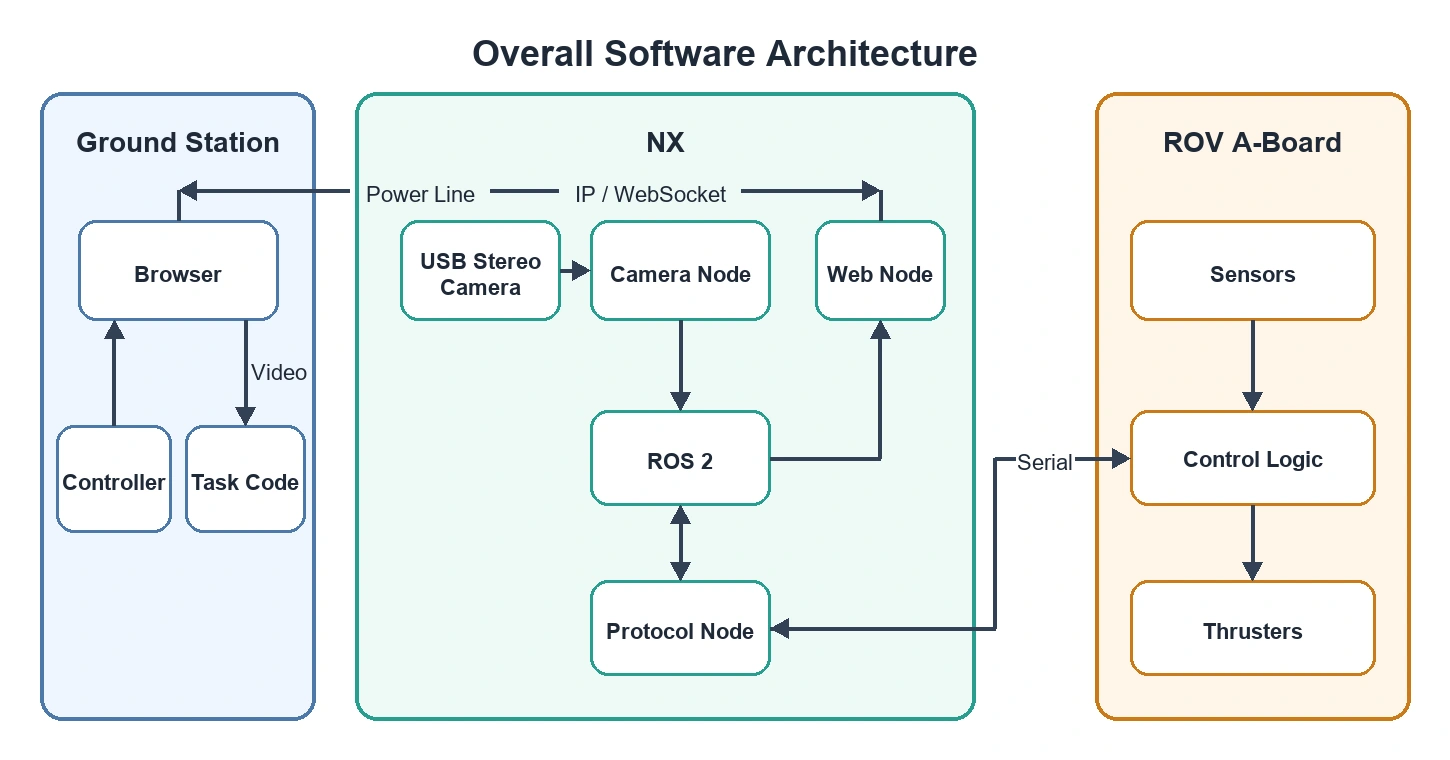
The Jetson Orin NX runs ROS 2 camera, protocol, and web services. It exchanges commands and sensor telemetry with the A-board over serial, and connects to the ground station through the power-line communication link. This separates real-time vehicle control from video delivery and operator interaction.
Working with the Robot
My experience includes hands-on robot debugging and maintenance alongside estimation work. The practical focus is making the path from a connected sensor to a usable estimate and a predictable physical response work as a complete system.
Sensors and installation
Sensor mounting, orientation, power, and communication interfaces connect the physical assembly to meaningful measurements.
Embedded integration
Sensor data, serial communication, and control feedback connect the A-board with the Jetson and the operator's telemetry.
Physical debugging
Debugging and maintenance bring the software signals back to the real robot's wiring, mechanical assembly, and response in water.
This project complements my simulation-based estimation work with practical experience in sensing hardware, embedded systems, and robot maintenance.
MATE Competition Result
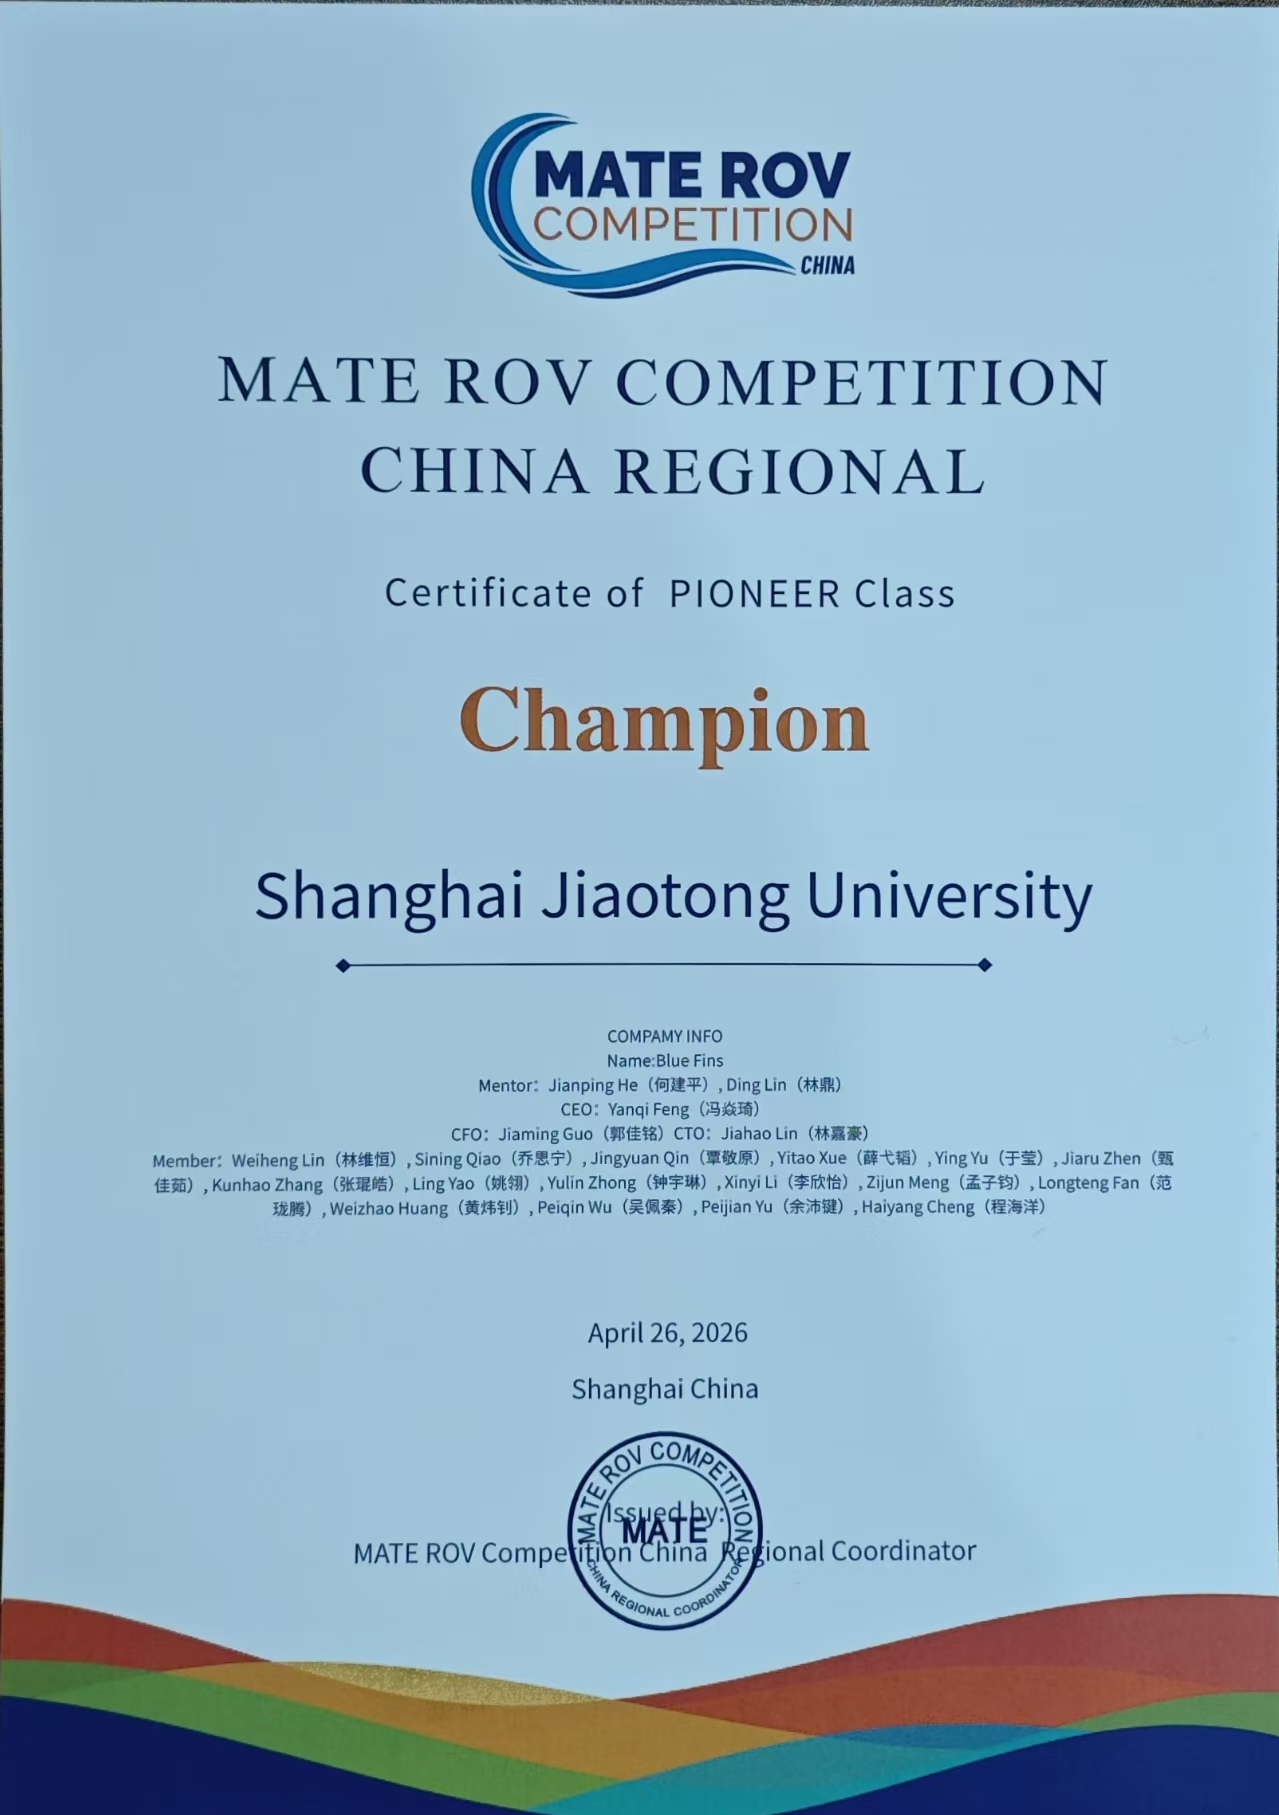
I participated with Shanghai Jiao Tong University’s Blue Fins, which received the PIONEER Class Champion title at the 2026 MATE ROV Competition China Regional, held in Shanghai on April 26, 2026.
Platform overview poster, IMU installation, and system architecture: Blue Fins 2026 Technical Documentation. These illustrate the team platform; the personal focus described here is state estimation, hardware–software integration, and hands-on robot debugging and maintenance. Image sources.