Overview
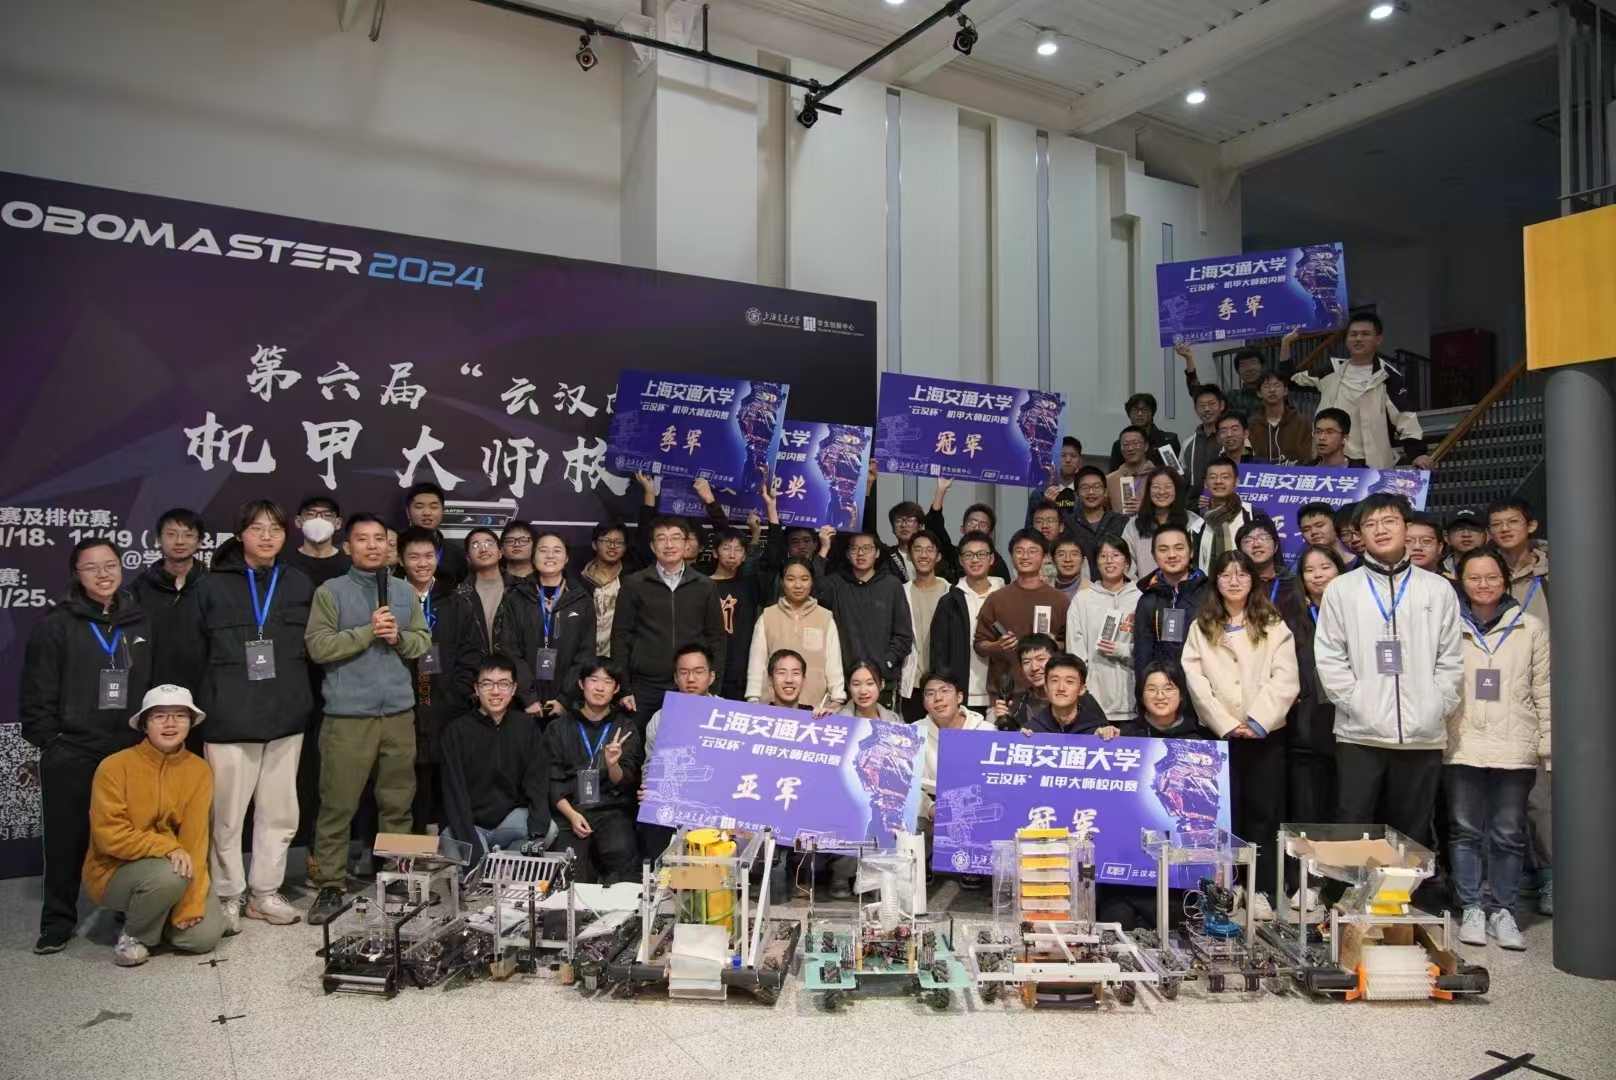
I participated in hardware and control work for the 2023 Shanghai Jiao Tong University RoboMaster Yunhan Cup, receiving First Prize in the Hardware and Control track.
The work combined embedded programming, mechanical assembly, electrical integration, and on-robot debugging for gimbal and chassis motion.
Robot Hardware
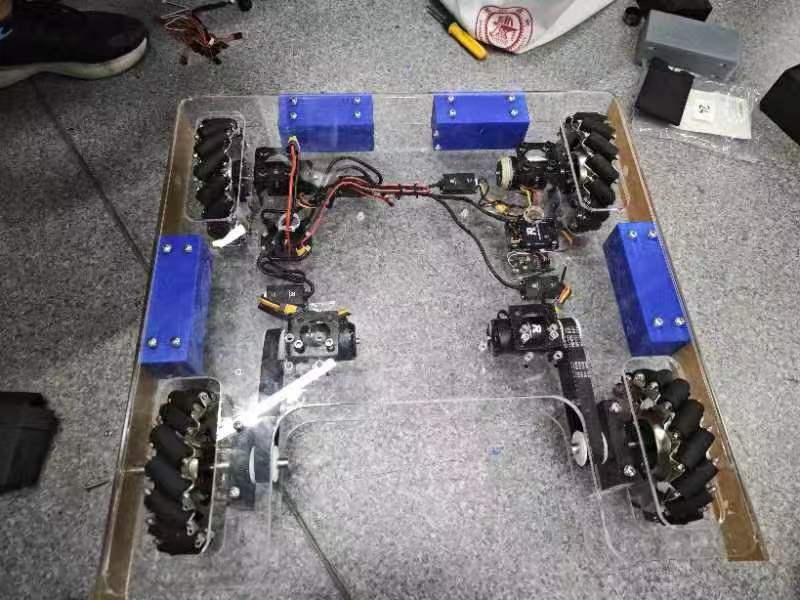
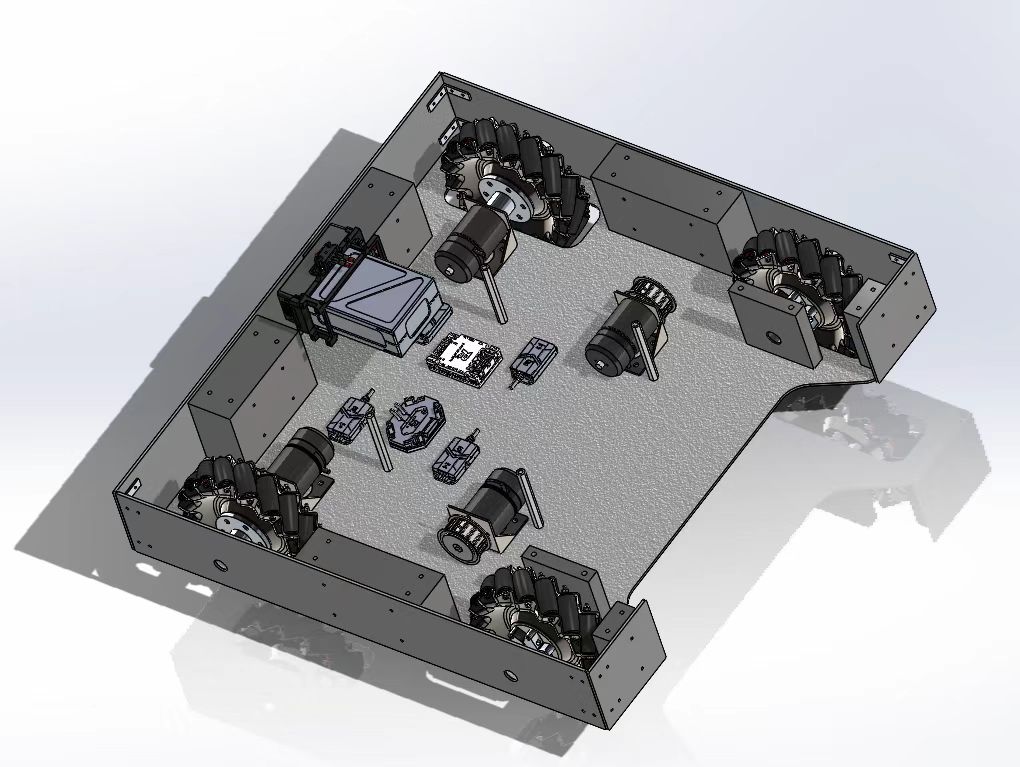
The robot prototype brought together the mechanical structure, actuators, electronics, and embedded controller. I supported mechanical assembly and electrical integration, checking the connections and actuator response before full-system debugging.
Embedded Control
I developed PID control in C++ on STM32 microcontrollers for gimbal and chassis motion. Debugging connected the controller output to the robot’s physical response, with attention to load, friction, power state, and mechanical looseness.
The development process progressed from individual modules to combined operation:
- Check power, communication, and actuator response.
- Introduce and tune the control logic on the assembled mechanism.
- Reproduce faults using the observed signals and mechanical behavior.
- Repeat integrated tests after changes to hardware or control parameters.
Competition
The project received First Prize in the Hardware and Control track. Working across mechanical, hardware, and software interfaces introduced me to the practical constraints of building and maintaining a competition robot.