About
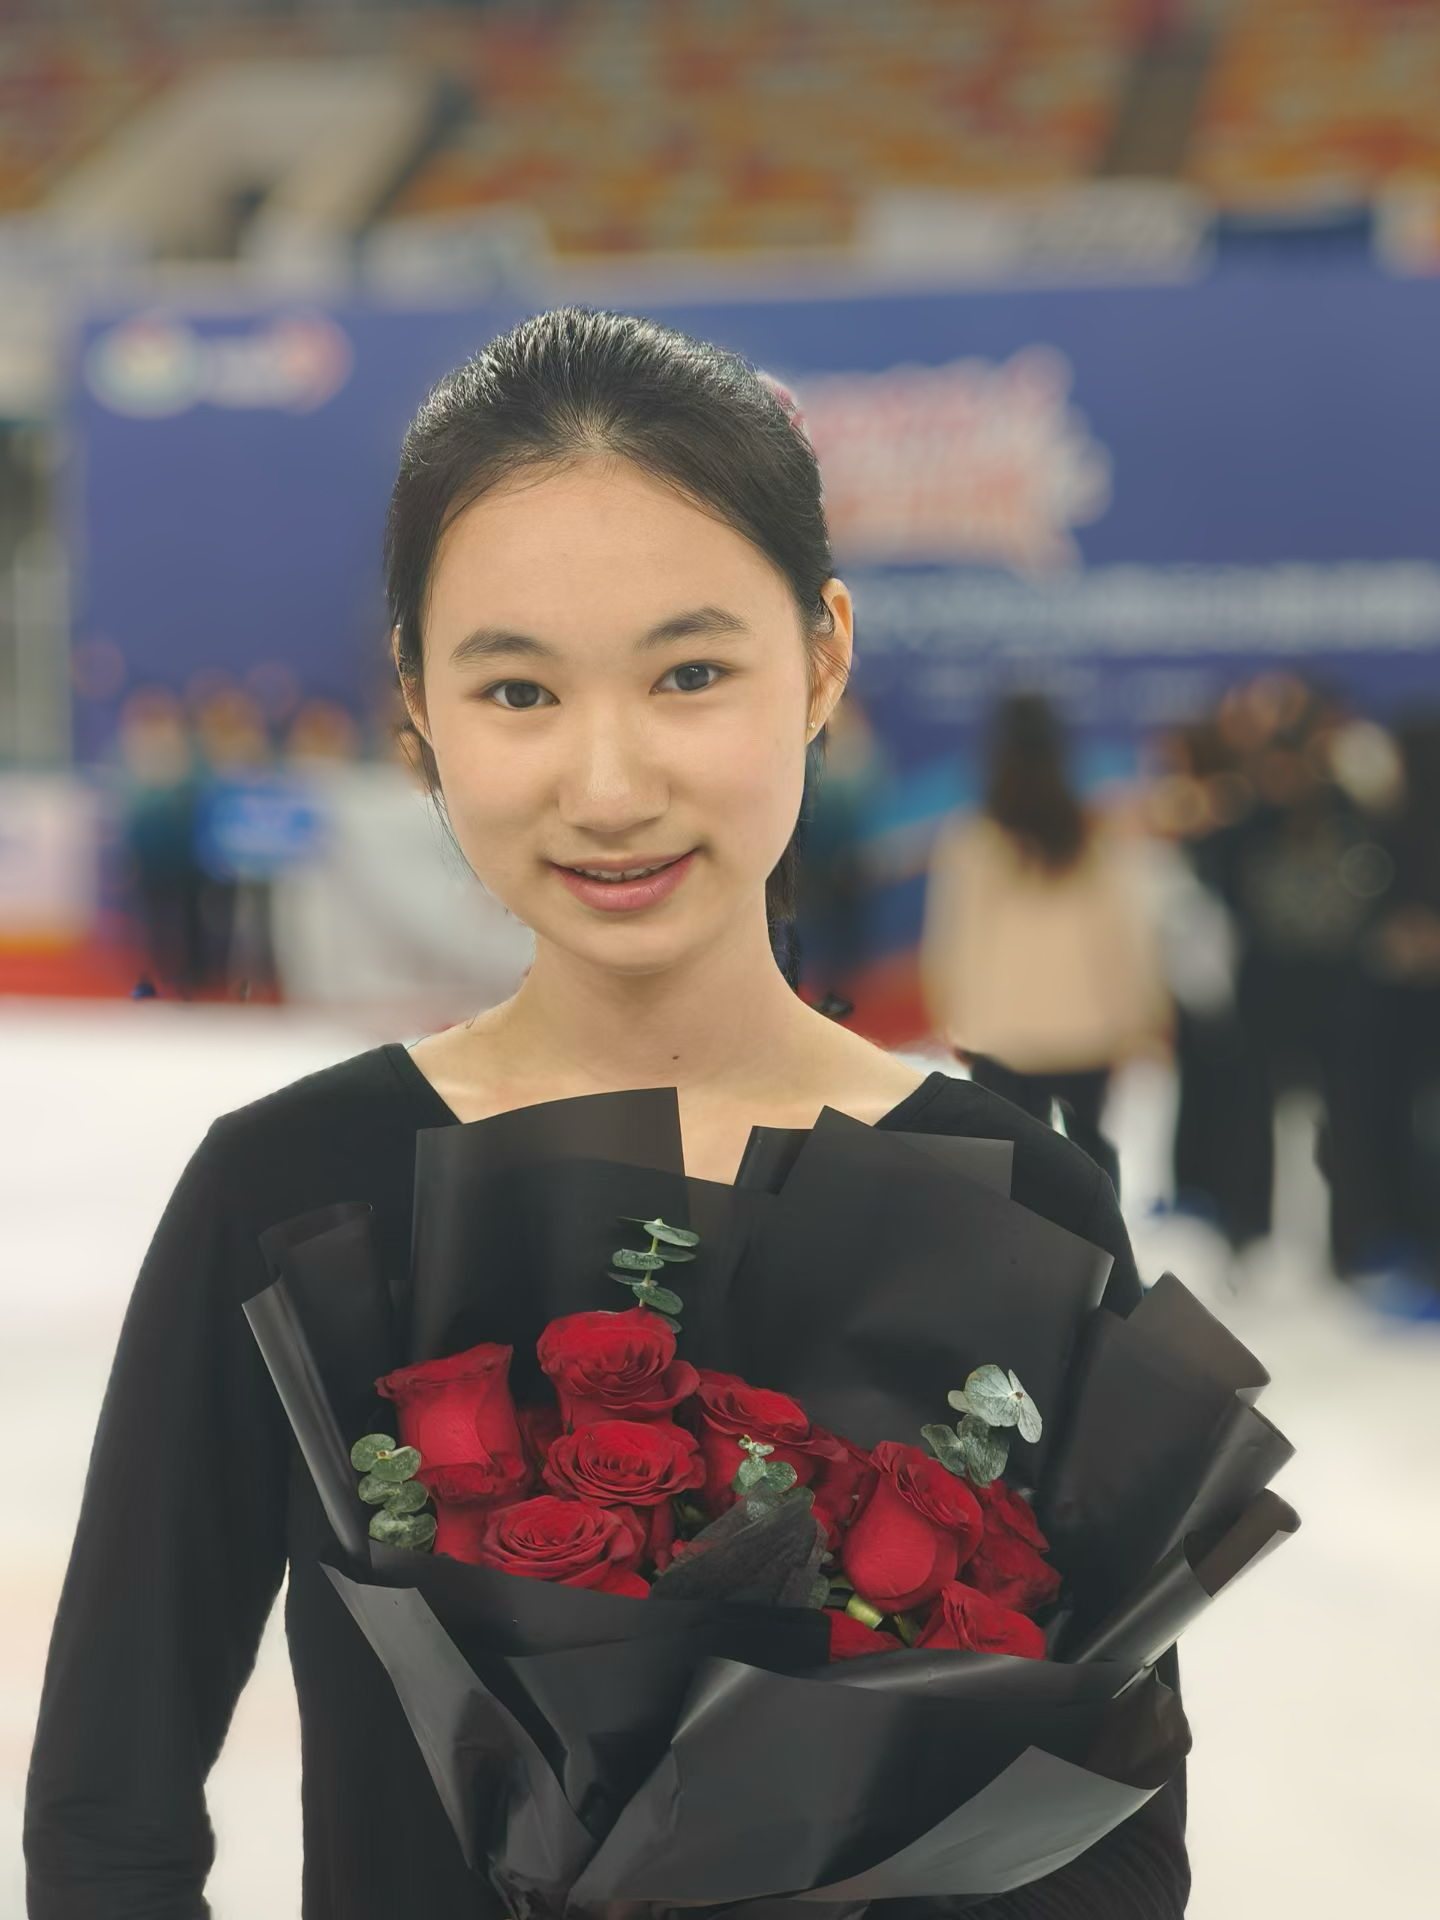
Yao Ling
Robotics · Distributed Optimization · Secure Control
B.Eng. candidate at Shanghai Jiao Tong University working on robotics, 4D-radar planning, distributed optimization, and secure control.
zero-in-ur-area@sjtu.edu.cn
Hello
I am Yao Ling, an undergraduate in IntelliSense Engineering at Shanghai Jiao Tong University and a former Computer Science exchange student at KTH Royal Institute of Technology.
Across my projects, I have repeatedly encountered the same question: what information does an autonomous system really need to make a good decision? I study this question through robust sensing, communication-efficient optimization, multi-agent coordination, and secure control.
Education
- Shanghai Jiao Tong University, B.Eng. Candidate in IntelliSense Engineering, 2023-2027
- KTH Royal Institute of Technology, Computer Science Exchange Student, Aug. 2025-Jan. 2026; four graduate-level courses
Research Interests
- Reliable decision-making for autonomous and networked systems
- Multimodal sensing and trajectory planning
- Distributed optimization and multi-agent coordination
- Secure and privacy-aware control
Publications
- Radar2Plan: Benchmarking 4D Radar for End-to-End Open-Loop Ego-Trajectory Planning - First author; submitted to ICRA 2027.
- High-Efficiency Distributed Nonconvex Optimization Design with Certified Stopping Rule - First author; accepted to IEEE CDC 2026.
- Secure Cyber-Physical Systems against Intent-Inference Attacks - First author; submitted to ACC 2027.
- Enhanced Follower Framework for Lifelong Multi-Agent Path Finding - Co-author; published at CCC 2026.
Research Projects
- Radar2Plan: A modular benchmark that compares camera, 4D radar, and LiDAR for real-world open-loop trajectory planning across four planning architectures and 12 operating conditions.
- CASO: Chebyshev surrogate optimization with accelerated consensus, a distributedly verifiable stopping rule, and an epsilon-global optimality guarantee.
- Secure CPS: Defense mechanisms that protect control intent against inverse-optimal-control attacks under finite and asymptotic observations.
- Multi-Pose 3DGS Alignment: Marker-based SE(3) alignment of camera poses and sparse point clouds for joint reconstruction from several object poses.
- State Estimation for UAV Navigation: Controlled Unity comparisons of EKF, particle filtering, Augmented MCL, and hybrid estimation, including kidnapped-robot recovery.
- Space Robotics Sand Rover: A ROS rover integrating visual perception, localization, A* planning, and PD control for sand-terrain navigation.
- RoboMaster Hardware and Control: PID control on STM32, electrical integration, and field debugging for gimbal and chassis motion.
Technical Skills
- Robotics and Control: ROS, state estimation, motion planning, distributed optimization, multi-agent systems, PID control
- Machine Learning and Vision: PyTorch, OpenCV, YOLO, 3D Gaussian Splatting, multimodal sensor fusion
- Programming: Python, C++, MATLAB, C, C#, Node.js
After Hours
Outside research, I enjoy travel, board games, music, and sports. I also built an online multiplayer version of a social-deduction board game with Express and Socket.IO.